top of page
Home
Portfolio Page
My Portfolio
Welcome to my portfolio. Here you’ll find a selection of my work. Explore my projects to learn more about what I do.
Previous
01
ROS 2 Controlled TurtleBot(2 wheel bot) Simulation in NVIDIA Isaac Sim
Developed a ROS 2-integrated TurtleBot simulation in NVIDIA Isaac Sim by implementing a differential drive controller and enabling real-time robot navigation through published velocity commands.
02
Synthetic Data Generation Pipeline
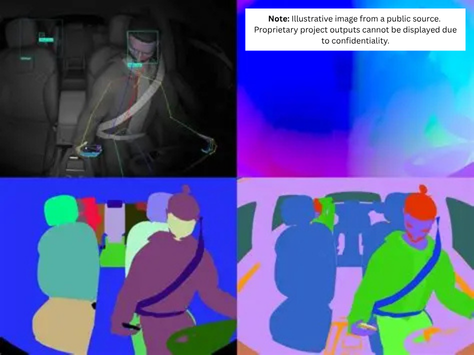
Built a scalable synthetic data generation pipeline for Driver Monitoring Systems (DMS) and Occupant Monitoring Systems (OMS) using Unreal Engine.
Developed photorealistic virtual environments, MetaHuman-based human simulations, and annotation-ready datasets to support AI model training and validation.
03
Driver Monitoring Simulation - Facial Expressions
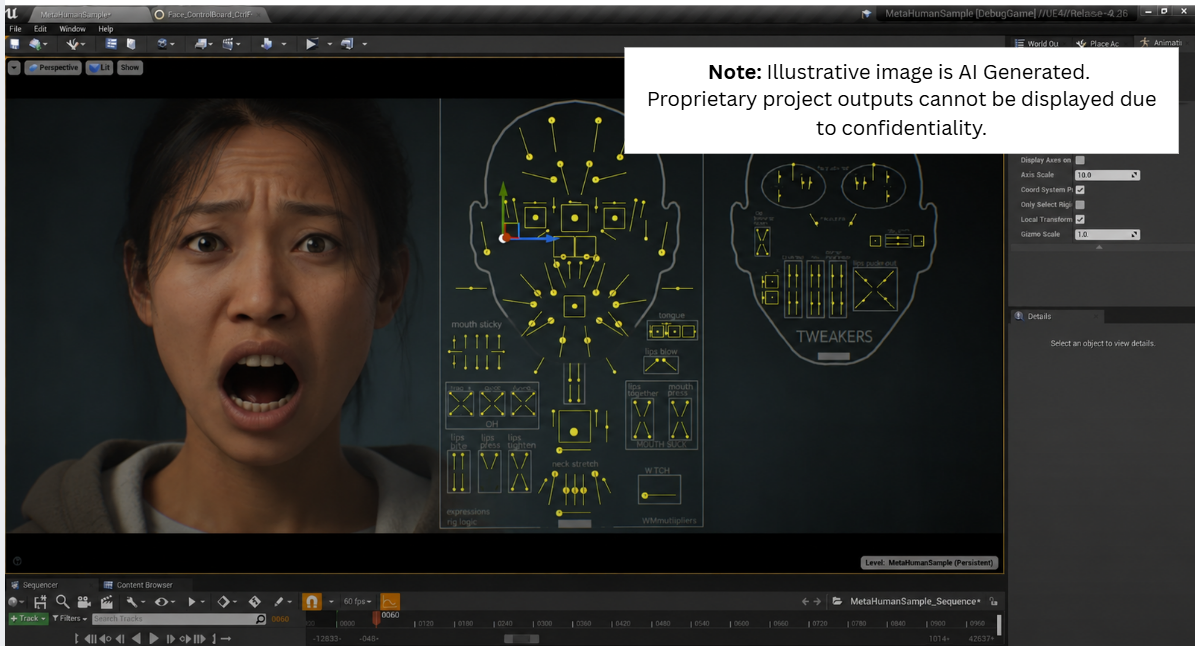
Created realistic driver behaviors for AI training including gaze, distraction, fatigue, and hand positions.
Leveraged Unreal Engine 5, MetaHumans to develop lifelike human expressions, animations, and occupant interactions.
04
Seatbelt cable simulation
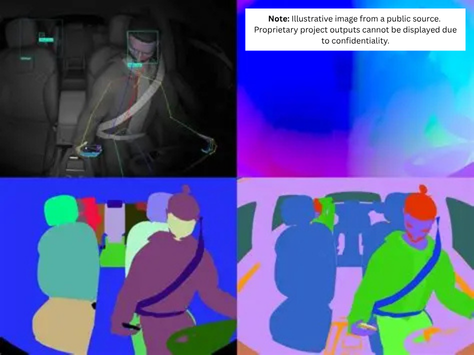
Developed an interactive digital twin of automotive seatbelt mechanisms using cable-based physics simulations.
Implemented in Unreal Engine using Cable Components, Blueprint scripting, and real-time physics to simulate realistic seatbelt behavior.
05
3D Rendering - Automotive HMI Prototype (Unity 3D)
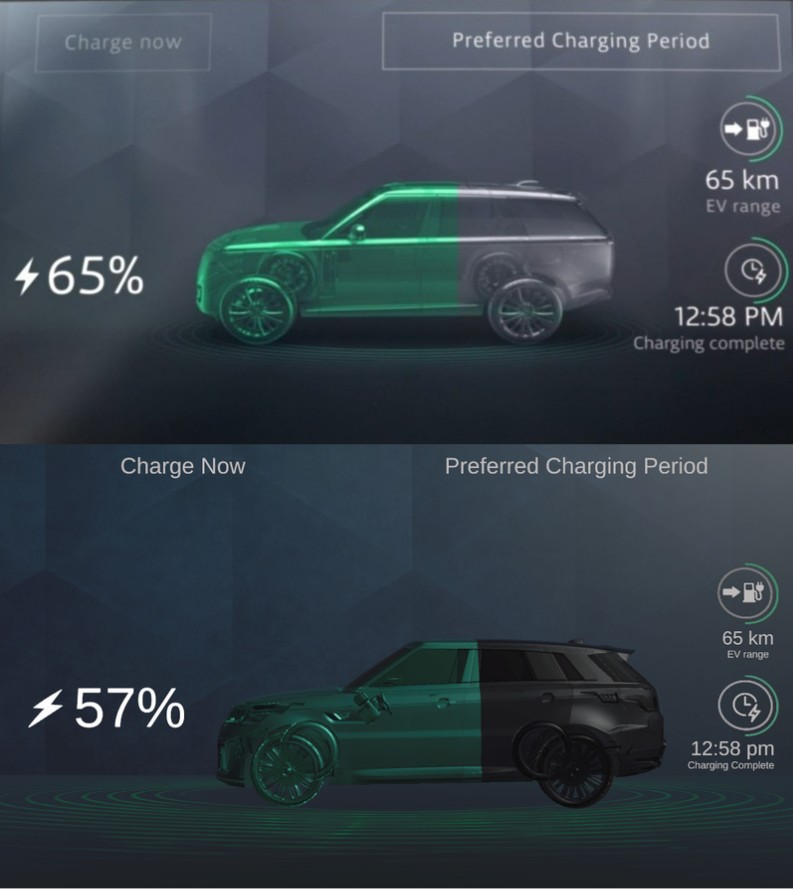
Recreated a premium electric vehicle charging interface in Unity, inspired by a production automotive HMI. Focused on responsive UI design, 3D visualization, animations, & real-time charging status.
06
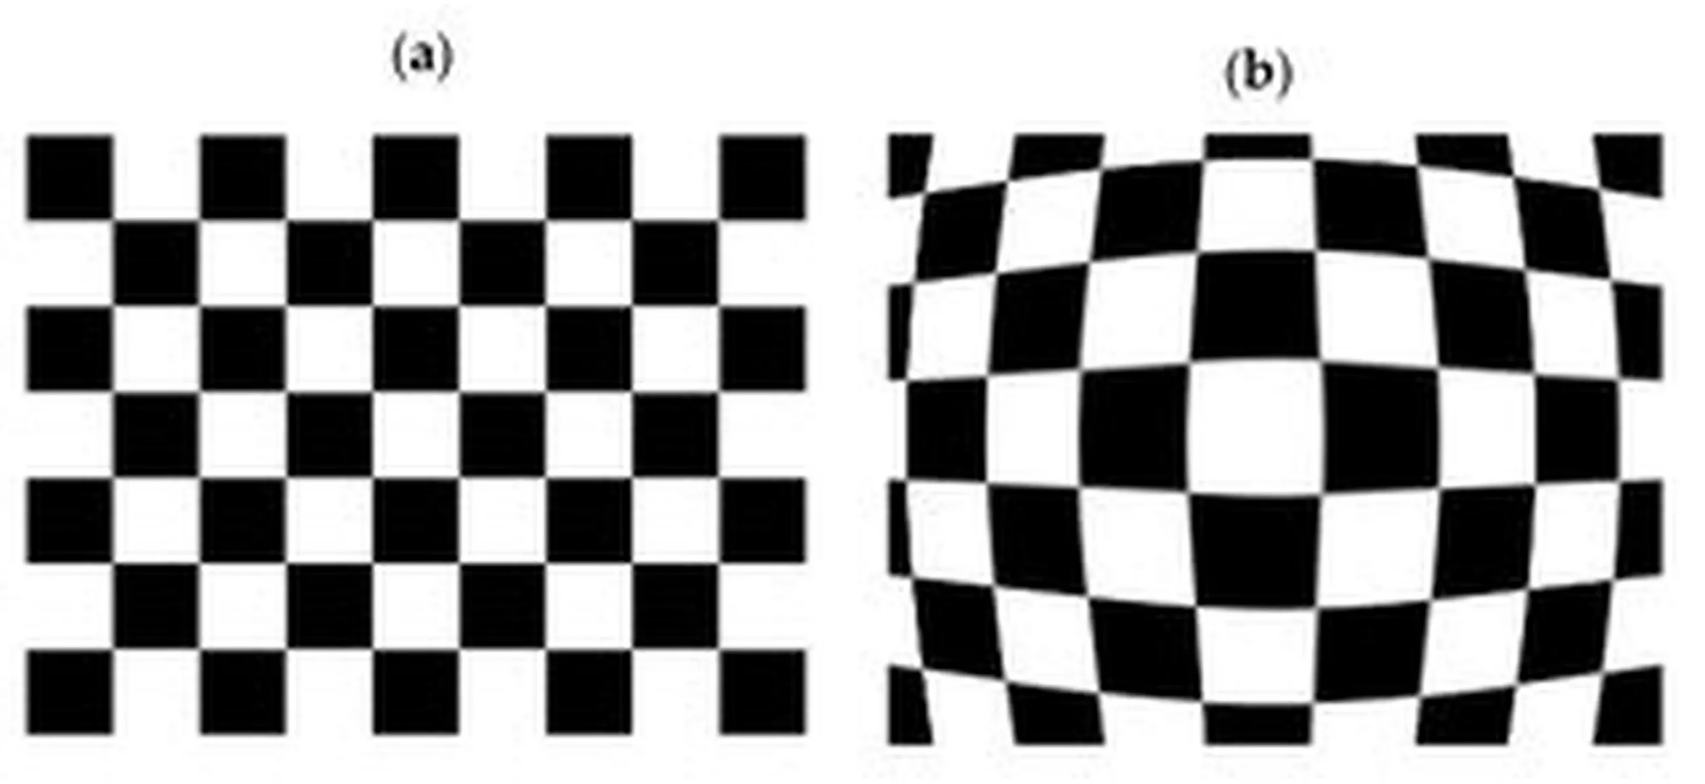
Synthetic to Realism with Camera Calibration & Lens Distortion
Implemented realistic automotive camera models by applying intrinsic parameters and lens distortion by integrating Unreal Engine and python.
Next
01 / 06
Close
Previous
Next
ROS 2 Controlled TurtleBot(2 wheel bot) Simulation in NVIDIA Isaac Sim
Developed a ROS 2-integrated TurtleBot simulation in NVIDIA Isaac Sim by implementing a differential drive controller and enabling real-time robot navigation through published velocity commands.
Go to link
0:00
/
0:00
01
ROS 2 Controlled TurtleBot(2 wheel bot) Simulation in NVIDIA Isaac Sim
Developed a ROS 2-integrated TurtleBot simulation in NVIDIA Isaac Sim by implementing a differential drive controller and enabling real-time robot navigation through published velocity commands.
02
Synthetic Data Generation Pipeline
Built a scalable synthetic data generation pipeline for Driver Monitoring Systems (DMS) and Occupant Monitoring Systems (OMS) using Unreal Engine.
Developed photorealistic virtual environments, MetaHuman-based human simulations, and annotation-ready datasets to support AI model training and validation.
03
Driver Monitoring Simulation - Facial Expressions
Created realistic driver behaviors for AI training including gaze, distraction, fatigue, and hand positions.
Leveraged Unreal Engine 5, MetaHumans to develop lifelike human expressions, animations, and occupant interactions.
04
Seatbelt cable simulation
Developed an interactive digital twin of automotive seatbelt mechanisms using cable-based physics simulations.
Implemented in Unreal Engine using Cable Components, Blueprint scripting, and real-time physics to simulate realistic seatbelt behavior.
05
3D Rendering - Automotive HMI Prototype (Unity 3D)
Recreated a premium electric vehicle charging interface in Unity, inspired by a production automotive HMI. Focused on responsive UI design, 3D visualization, animations, & real-time charging status.
06
Synthetic to Realism with Camera Calibration & Lens Distortion
Implemented realistic automotive camera models by applying intrinsic parameters and lens distortion by integrating Unreal Engine and python.
Synthetic Data Generation Pipeline
Driver Monitoring Simulation - Facial Expressions
Seatbelt cable simulation
3D Rendering - Automotive HMI Prototype (Unity 3D)
Synthetic to Realism with Camera Calibration & Lens Distortion
bottom of page